🤖 Robotics & Bio-Inspired
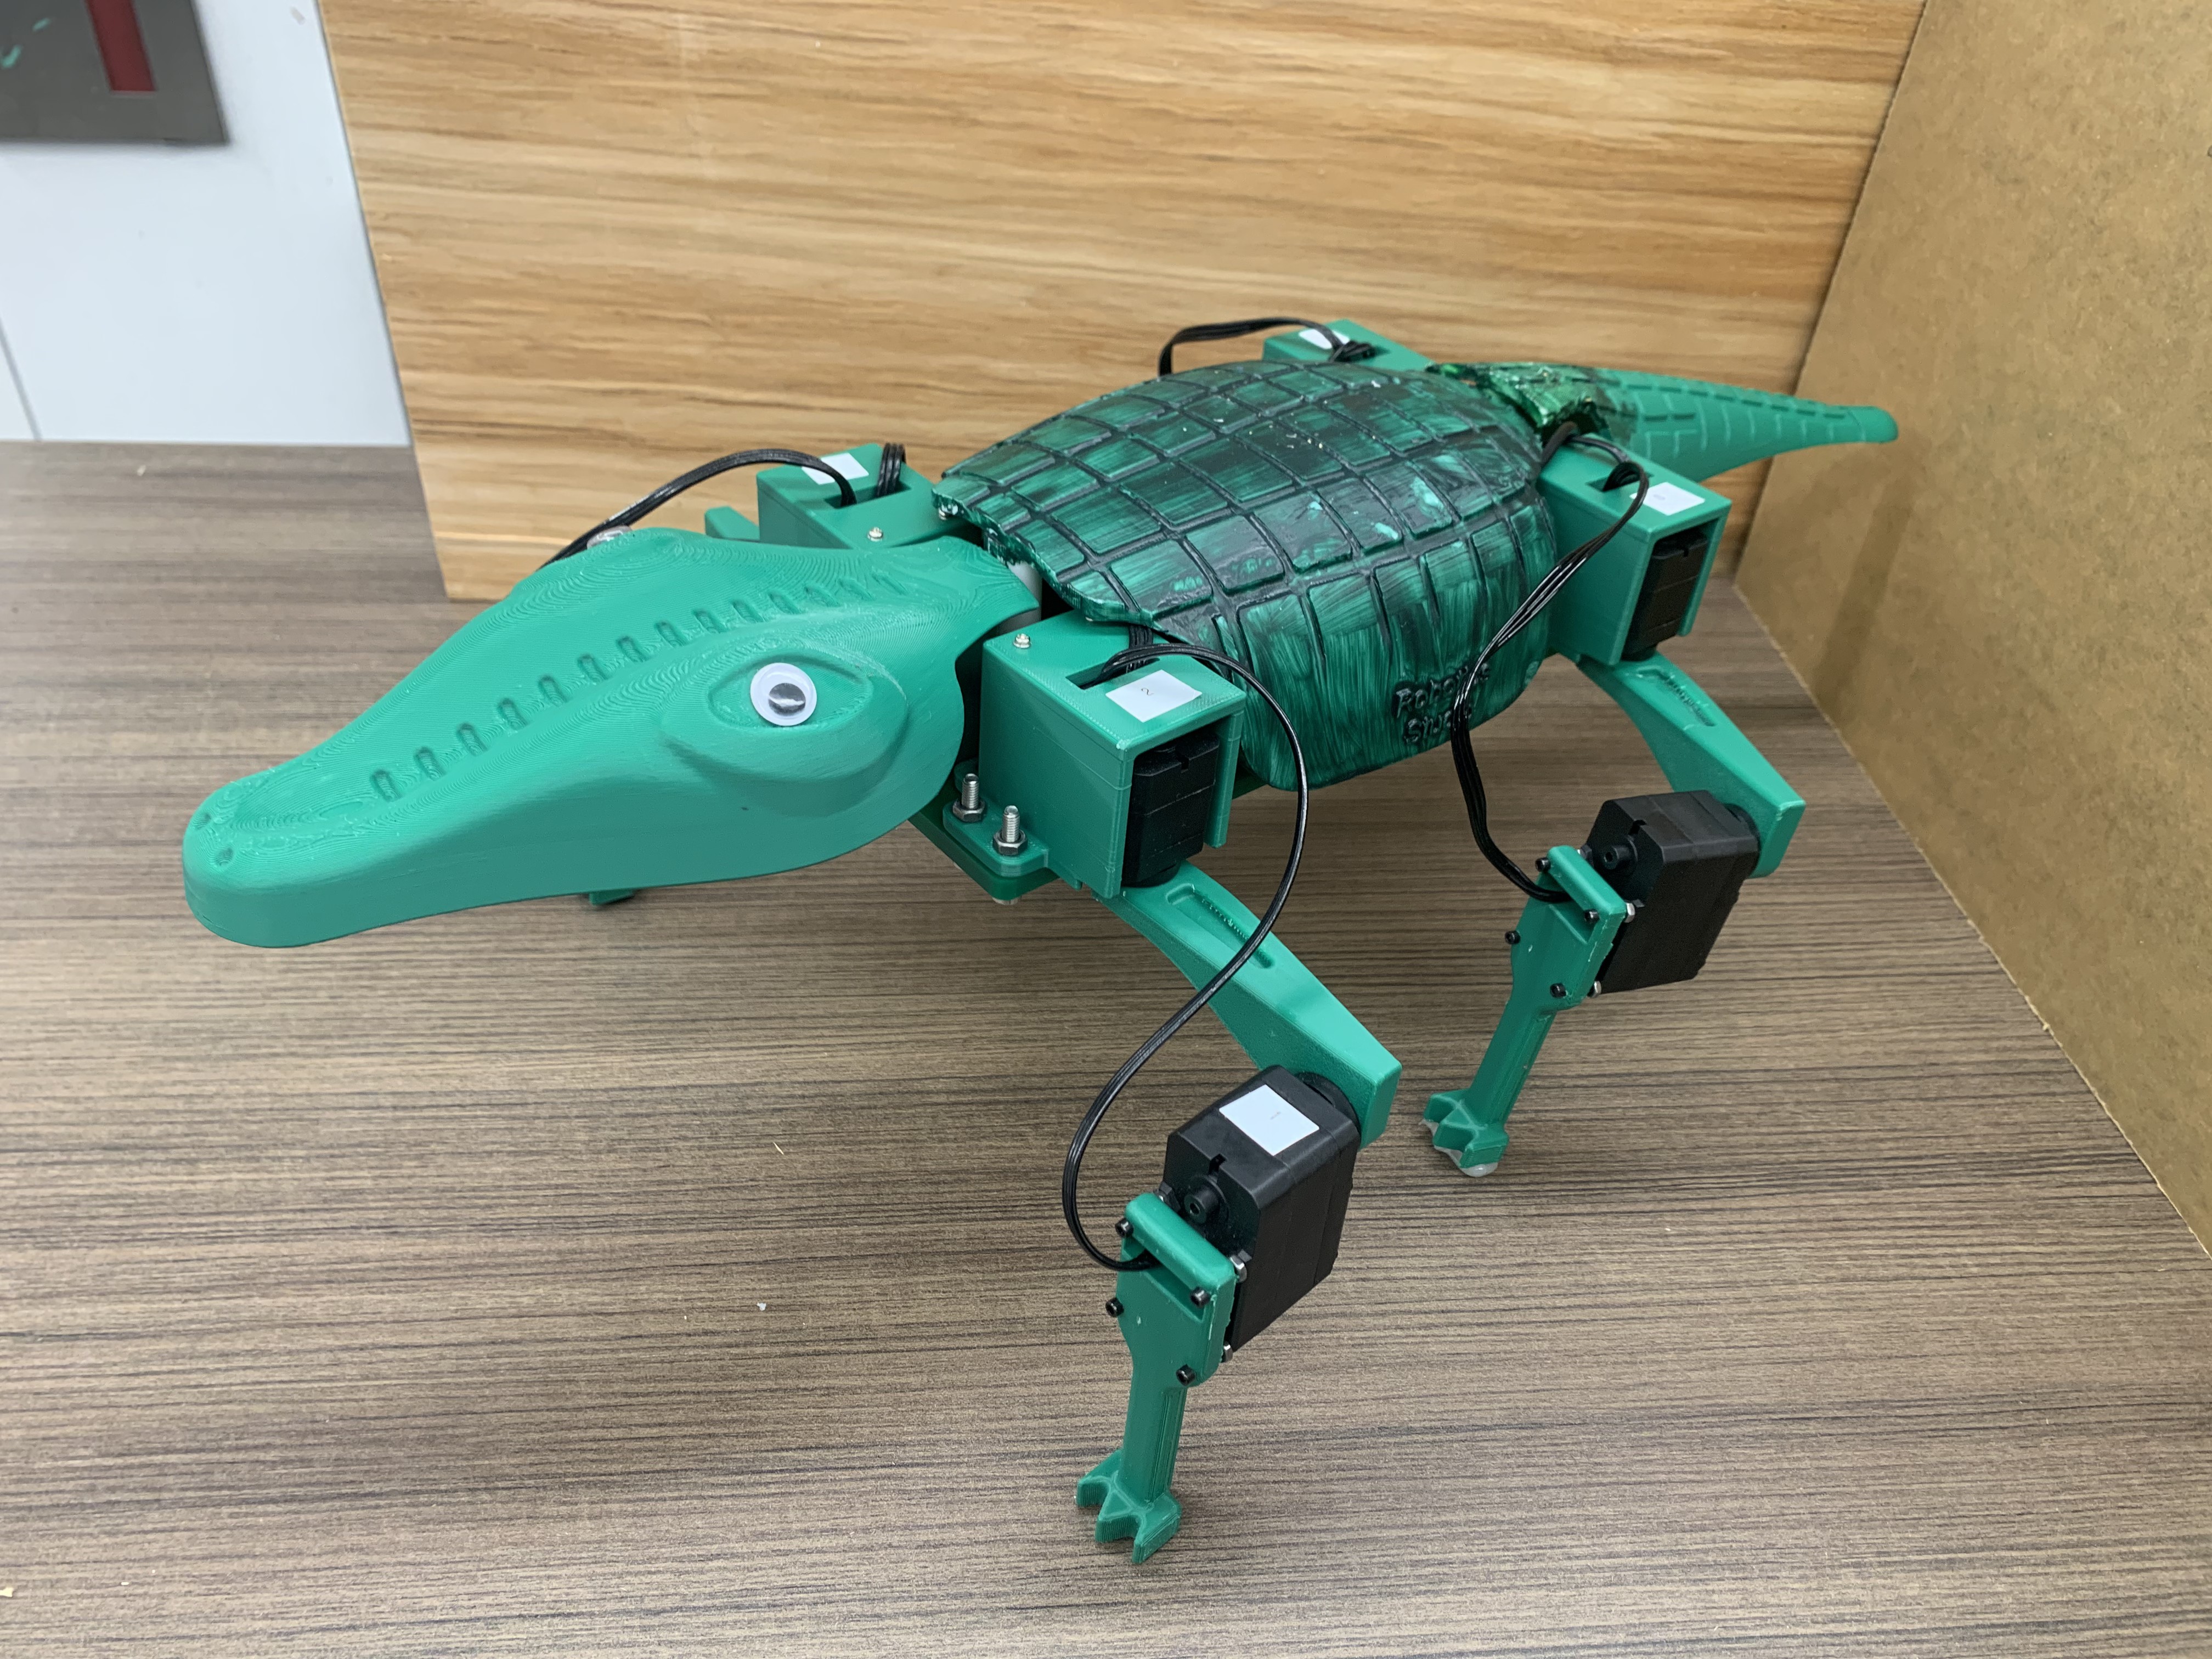
Bio-Inspired Crocodile Robot
Quadrupedal walking robot with synchronized 4-limb gait — fast and slow walk modes, validated through physical prototype and video.
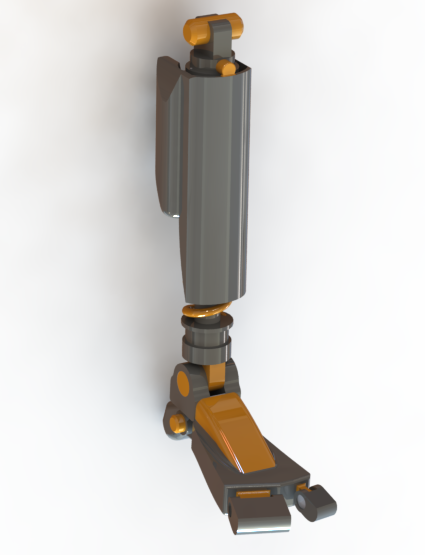
Bionic Foot with Ankle & Toe Joints
Biomechanically-accurate bionic prosthetic foot designed in SolidWorks with independent ankle and toe joint articulation.
🧠 Evolutionary Computation & AI
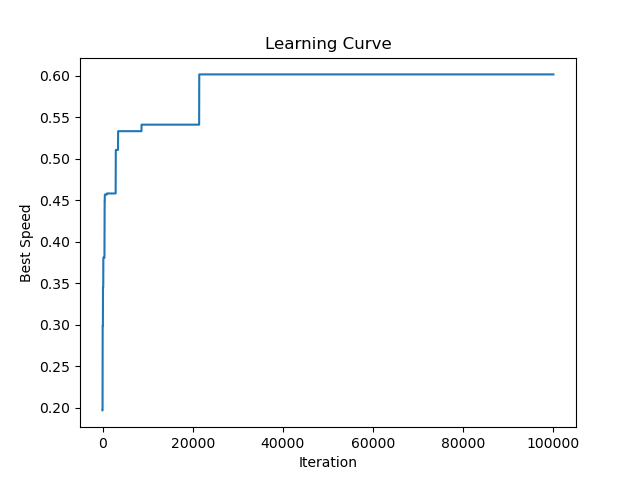
Evolving Soft Robots
Evolutionary algorithm + custom physics engine to evolve soft-body robot locomotion. Peak speed: 0.6 m/s over 100K iterations.
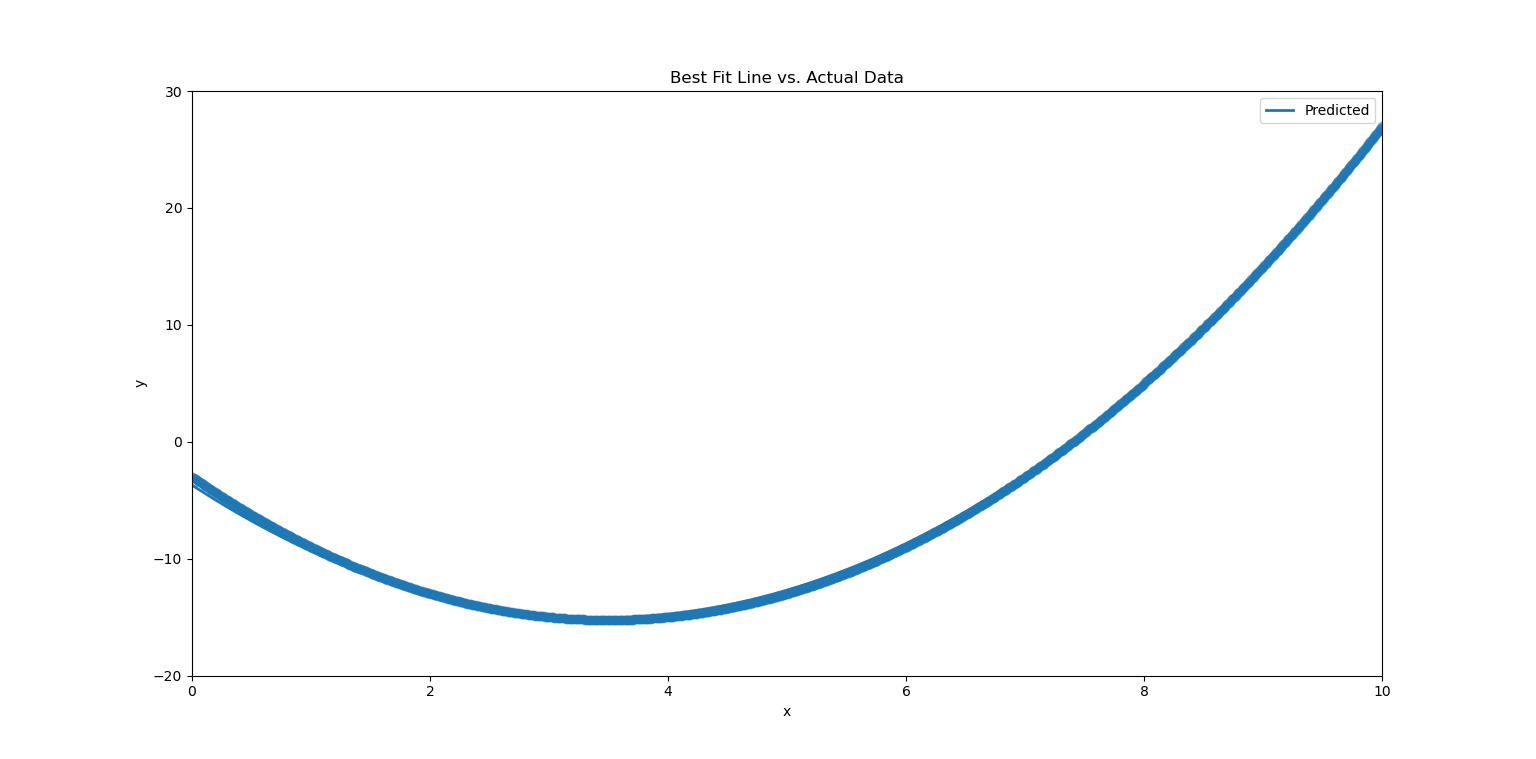
Symbolic Regression via Genetic Algorithm
GA-based symbolic regression to discover mathematical expressions from data — comparing hill climbers vs. full GA over 10K iterations.
🏭 Digital Manufacturing
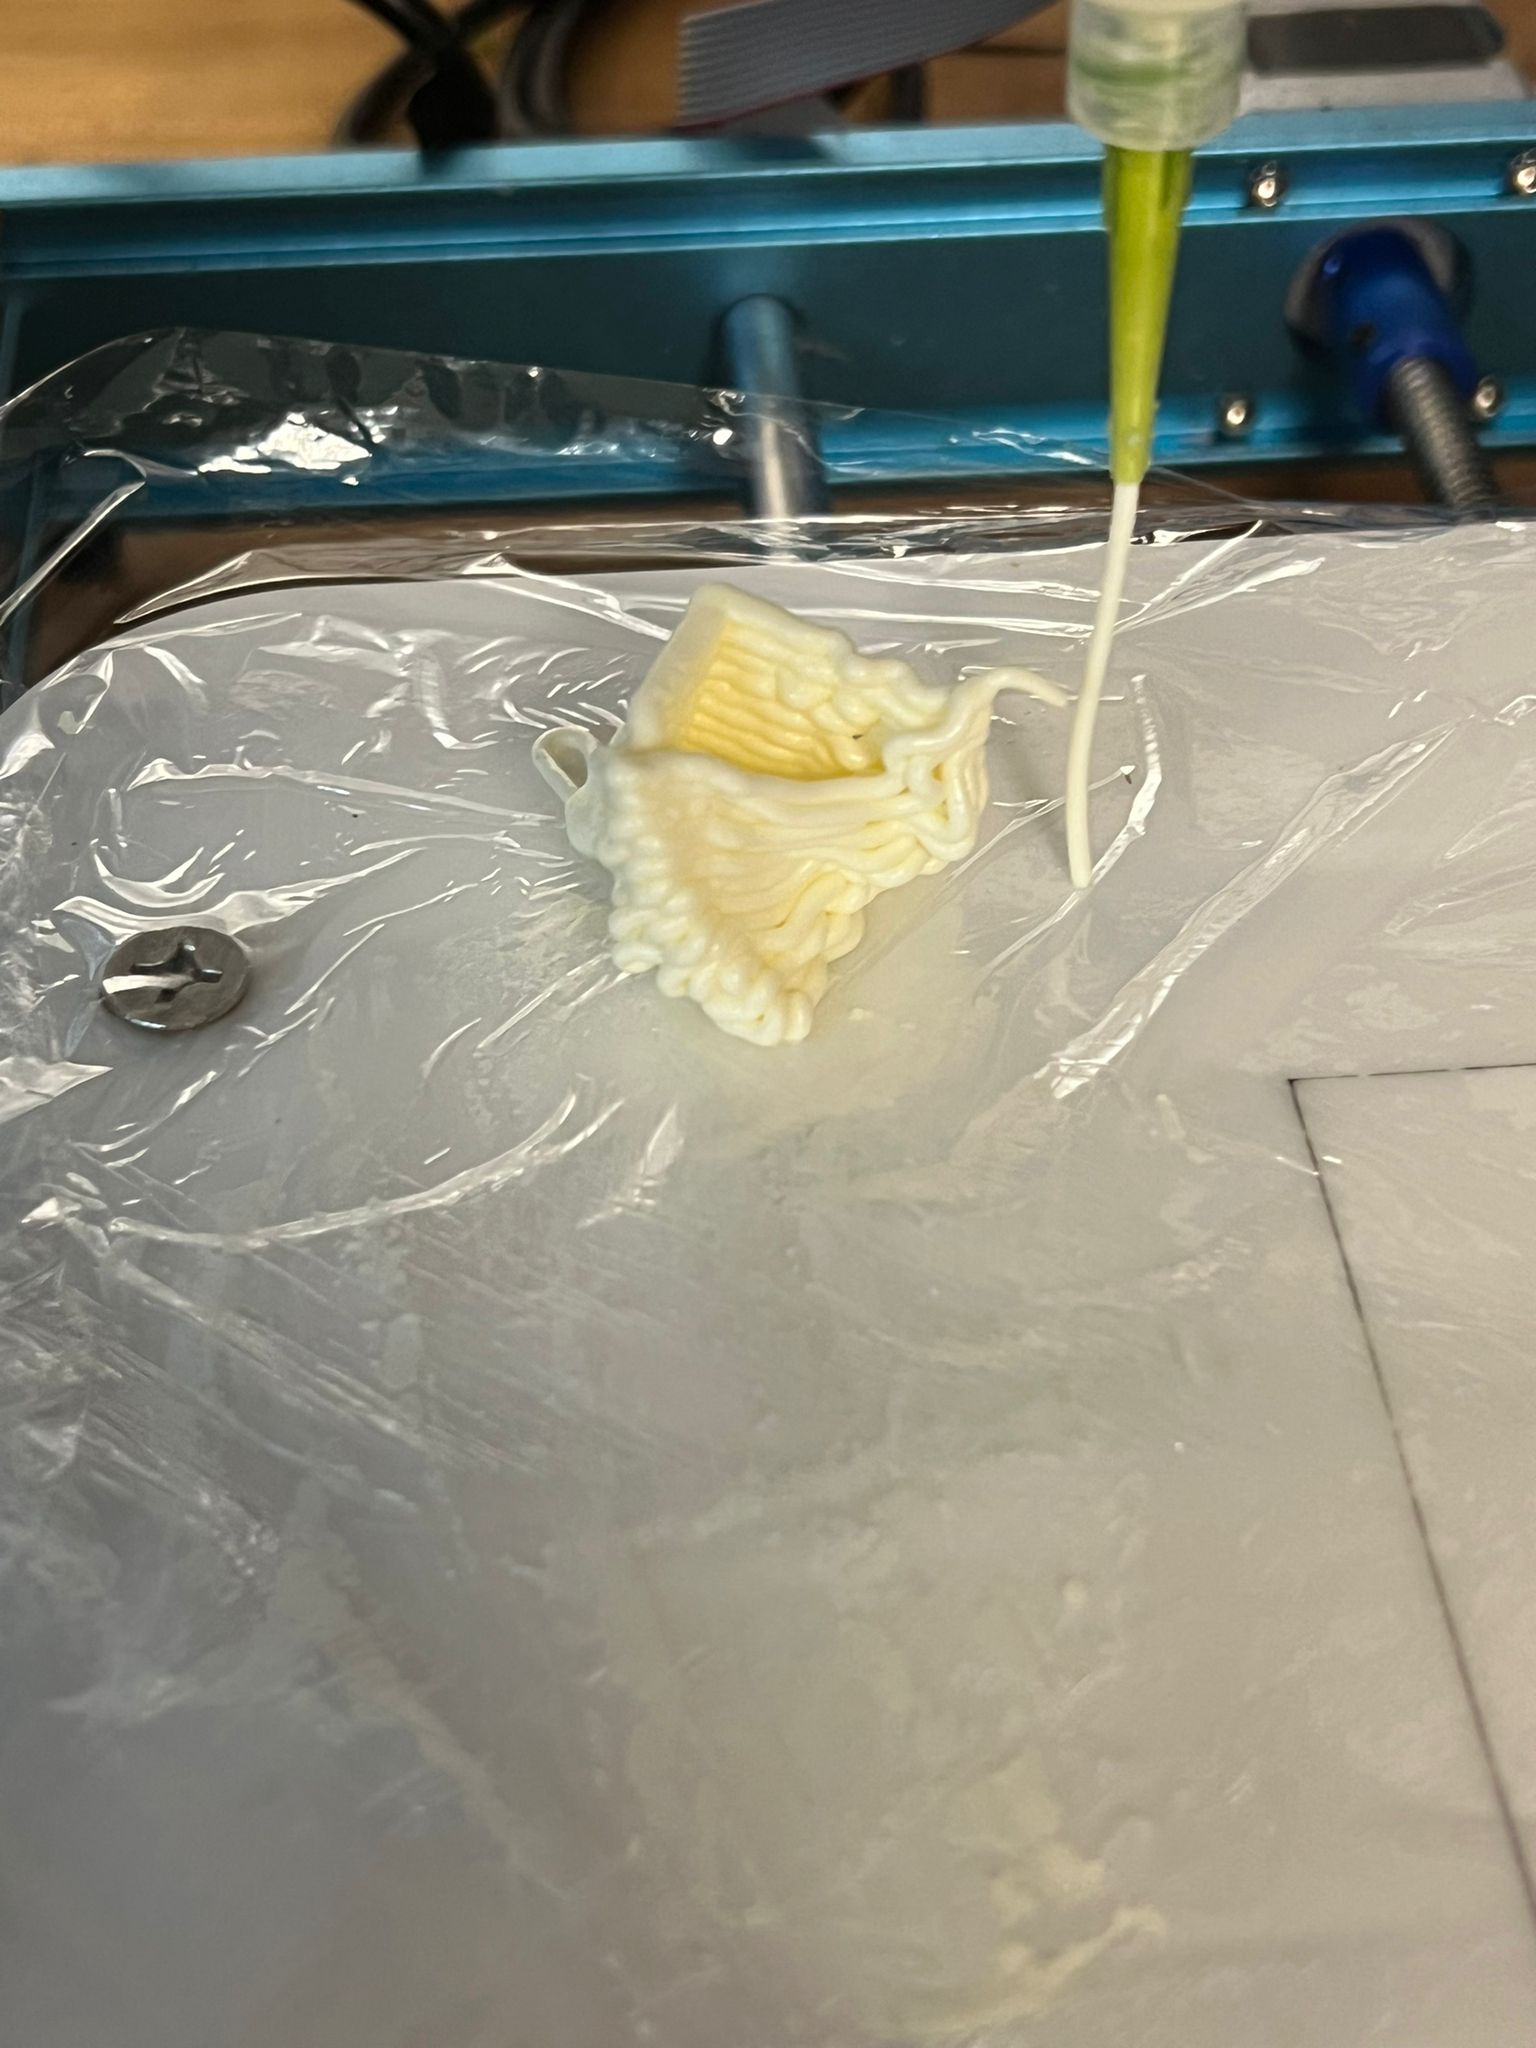
Advanced Techniques in Food Printing
Multi-material 3D-printed edible structures using a syringe-based bio-printer. Optimized across pyramids, spheres, and multi-material geometries.
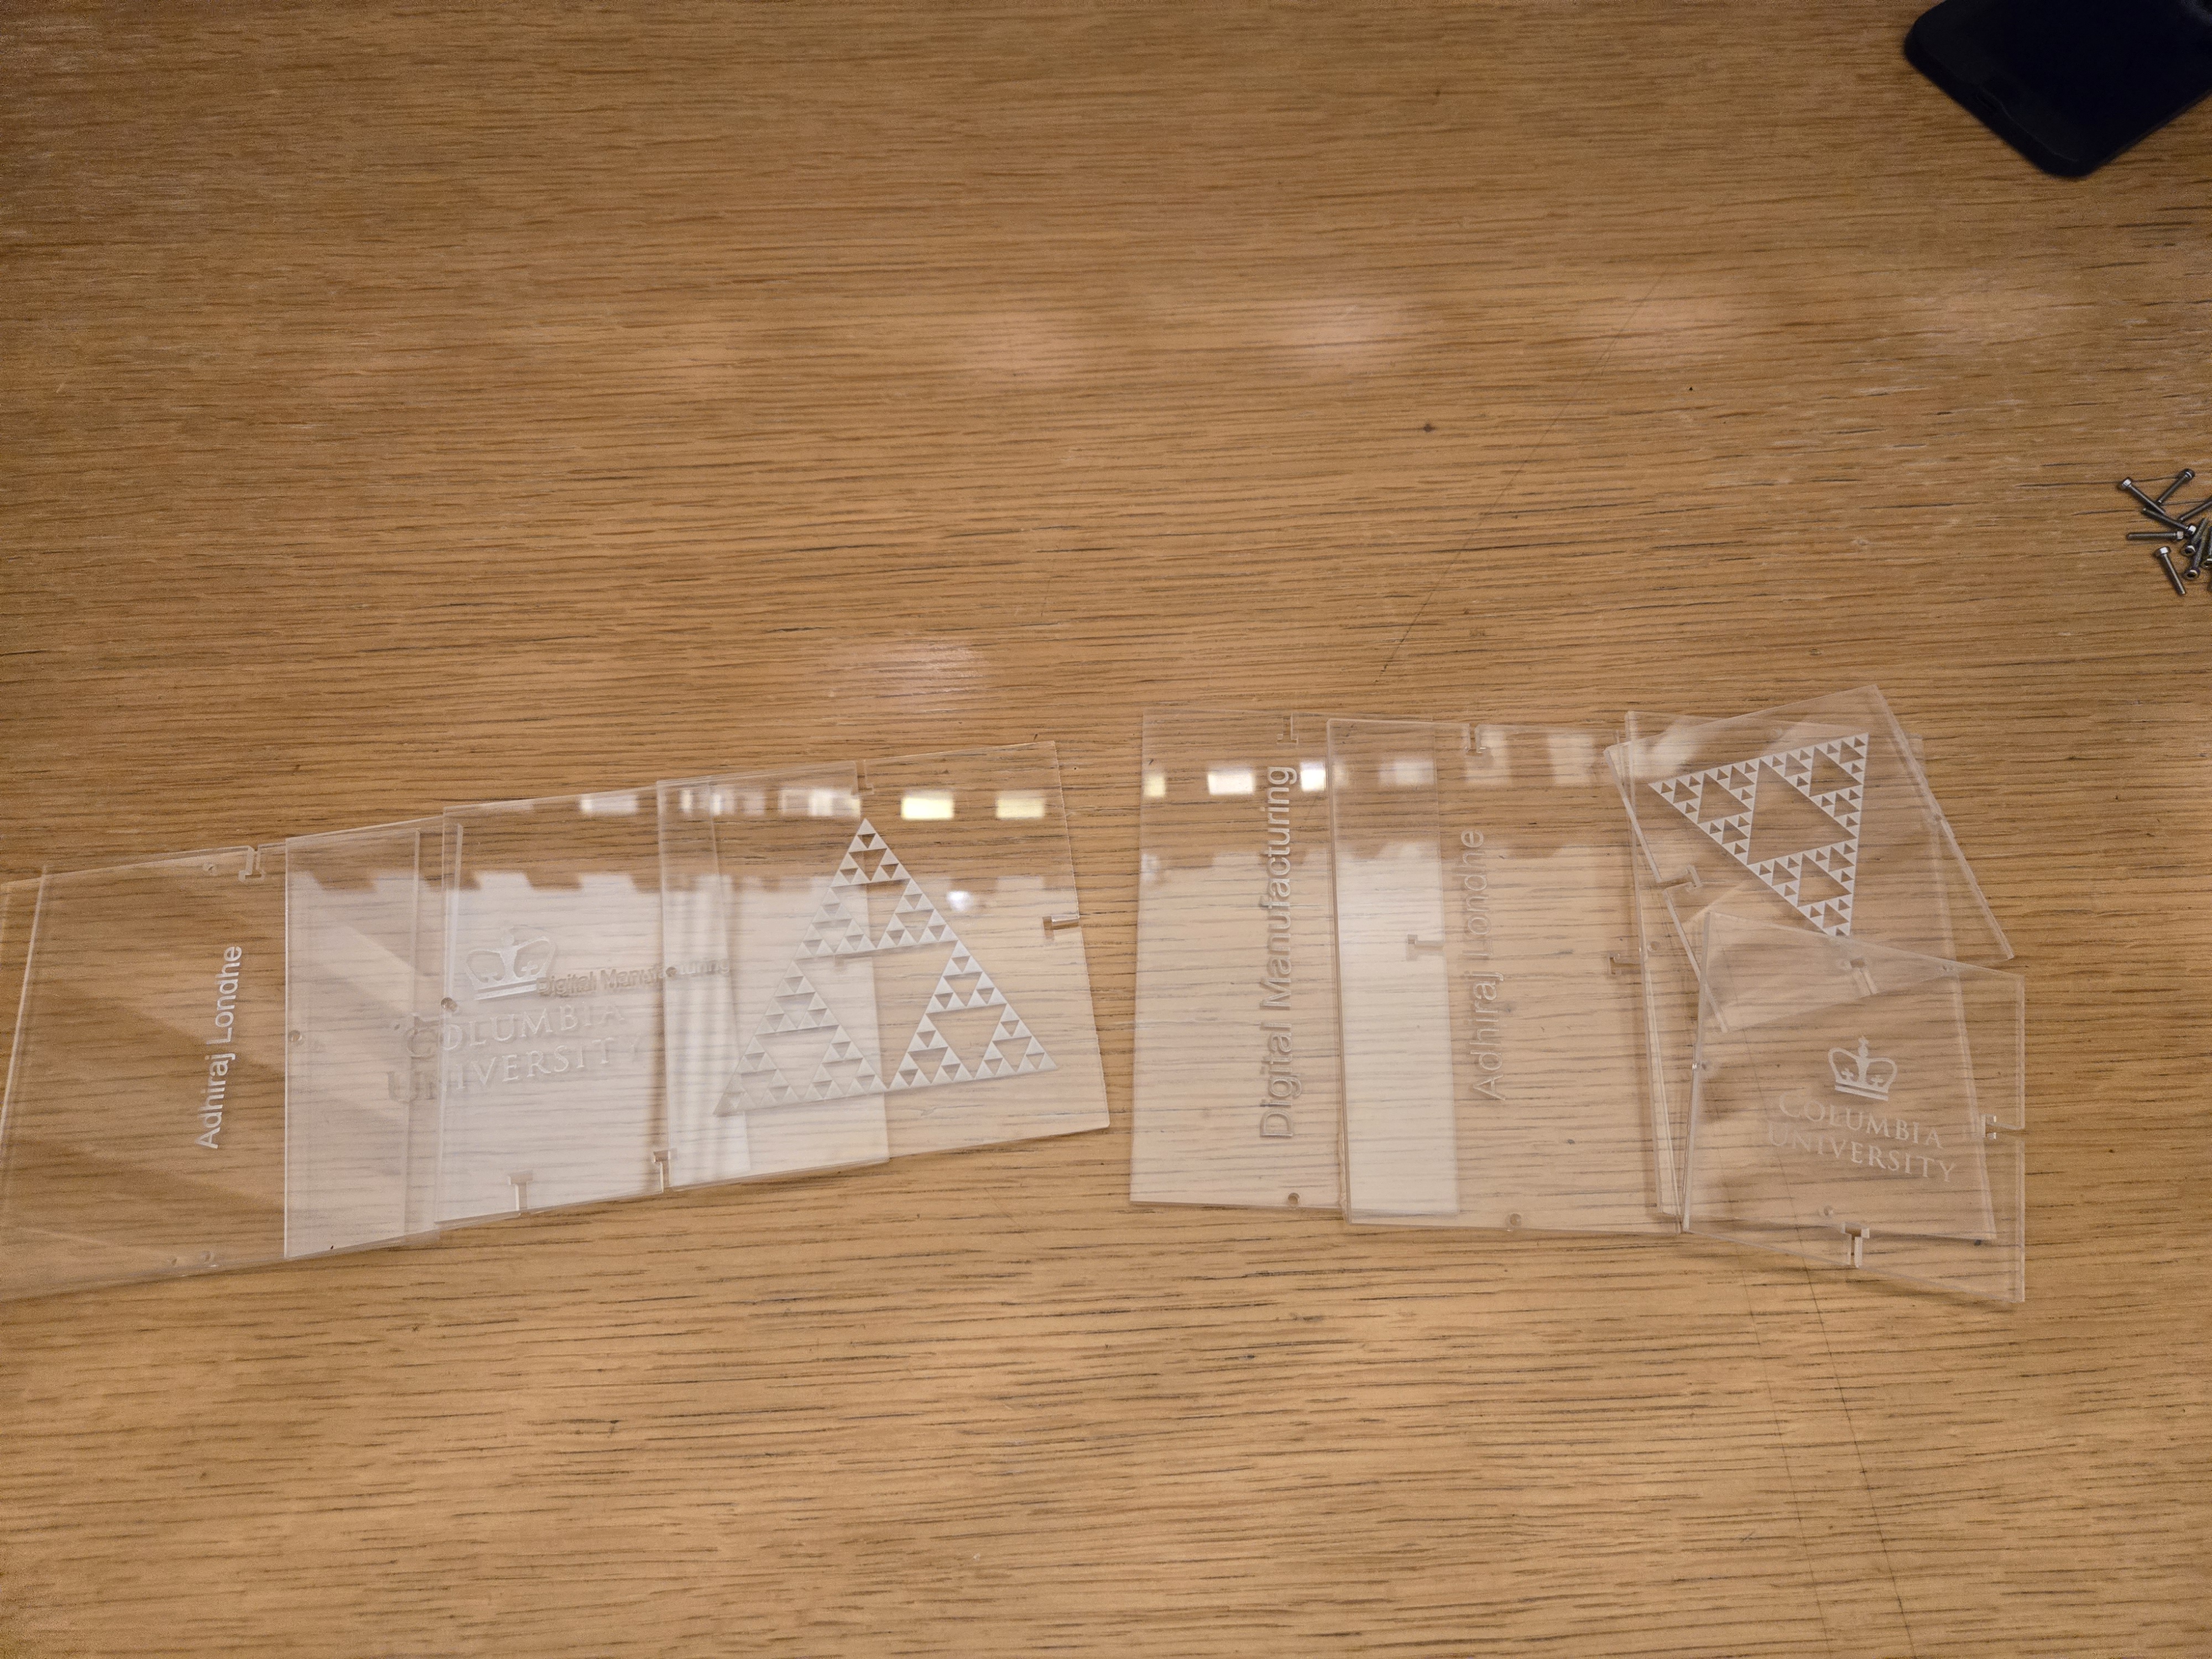
Software-Driven Fabrication
Parametric SVG tool generating laser-cut acrylic boxes with fractal engravings (Sierpiński, Koch). Automated panel layout and tab-slot joints.
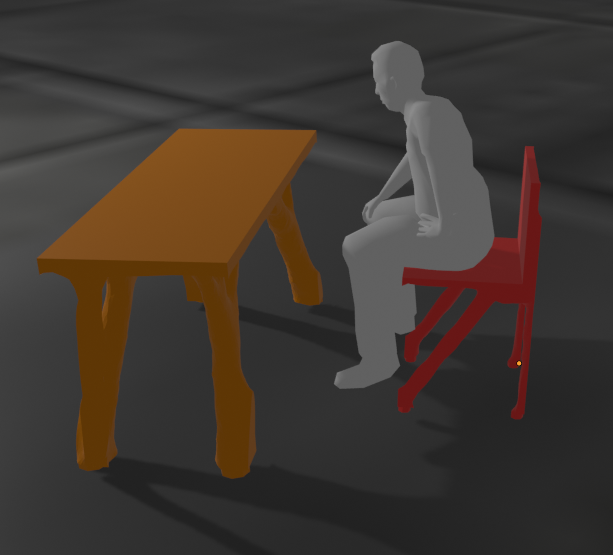
Topology Optimization
MATLAB-based SIMP topology optimization to minimize structural compliance — material-efficient structural layouts visualized in Blender.
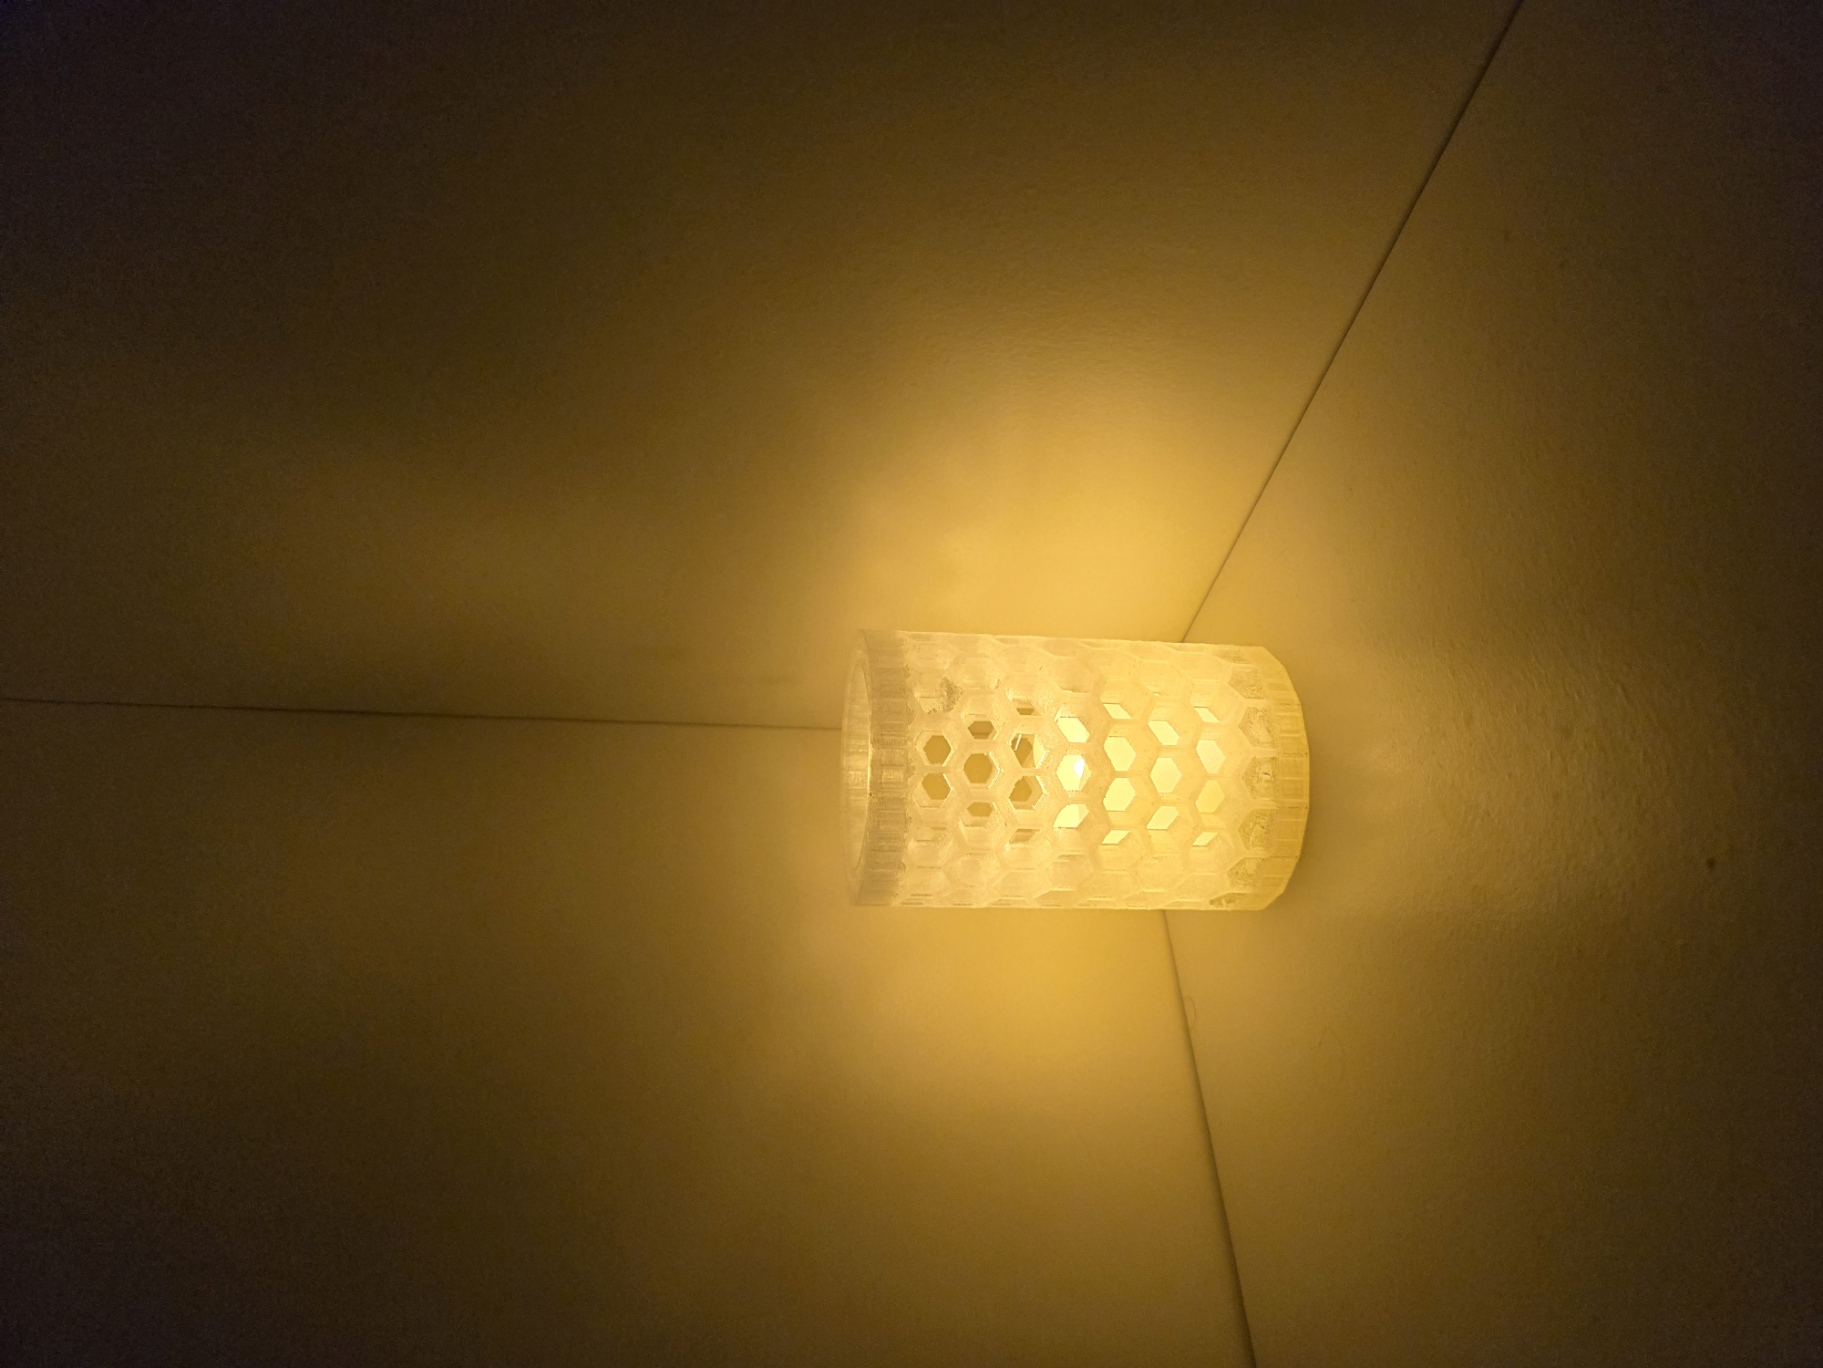
3D-Printed Parametric Lamp Shade
Algorithmically-generated honeycomb lattice lamp shade in OpenSCAD — stunning light diffusion through the hexagonal structure.
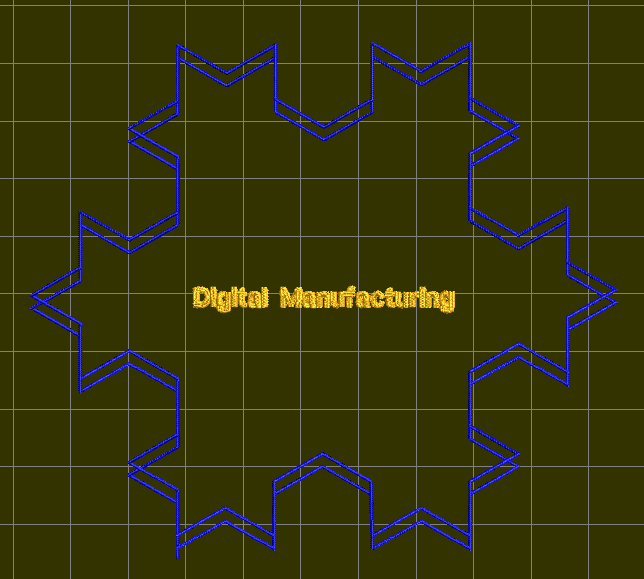
Algorithmic Embroidery — Koch Snowflake
Koch snowflake fractal embroidery programmatically generated in Python + InkStitch, executed on a CNC embroidery machine.