Video
🦠 Evolving Soft Robots — 100K Generation Evolution
Local Simulation Videos
100K Generation Run
Robot Zoo — Population Diversity
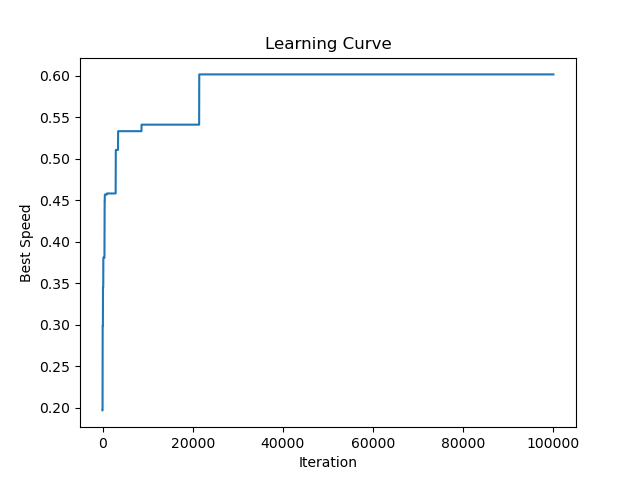
Learning Curves & Results
1 / 1
About This Project
Built a custom 2D physics engine and genetic algorithm from scratch in Python to evolve soft-body robots capable of locomotion. Each robot is represented as a spring-mass network; the GA selects and mutates the fittest individuals across generations.
Over 100,000 generations, the best robots achieved a peak speed of 0.6 m/s. The "zoo" video shows the diversity of evolved body plans — from crawlers to hoppers — demonstrating the algorithm's ability to discover varied locomotion strategies.
Course
Evolutionary Robotics — Columbia
Year
2023
Language
Python (NumPy, Matplotlib)
Peak Result
0.6 m/s over 100K generations