Video
🦎 Croc Robot — Walking Demonstration
Local Test Footage
Fast Walk Gait
Slow Walk Gait
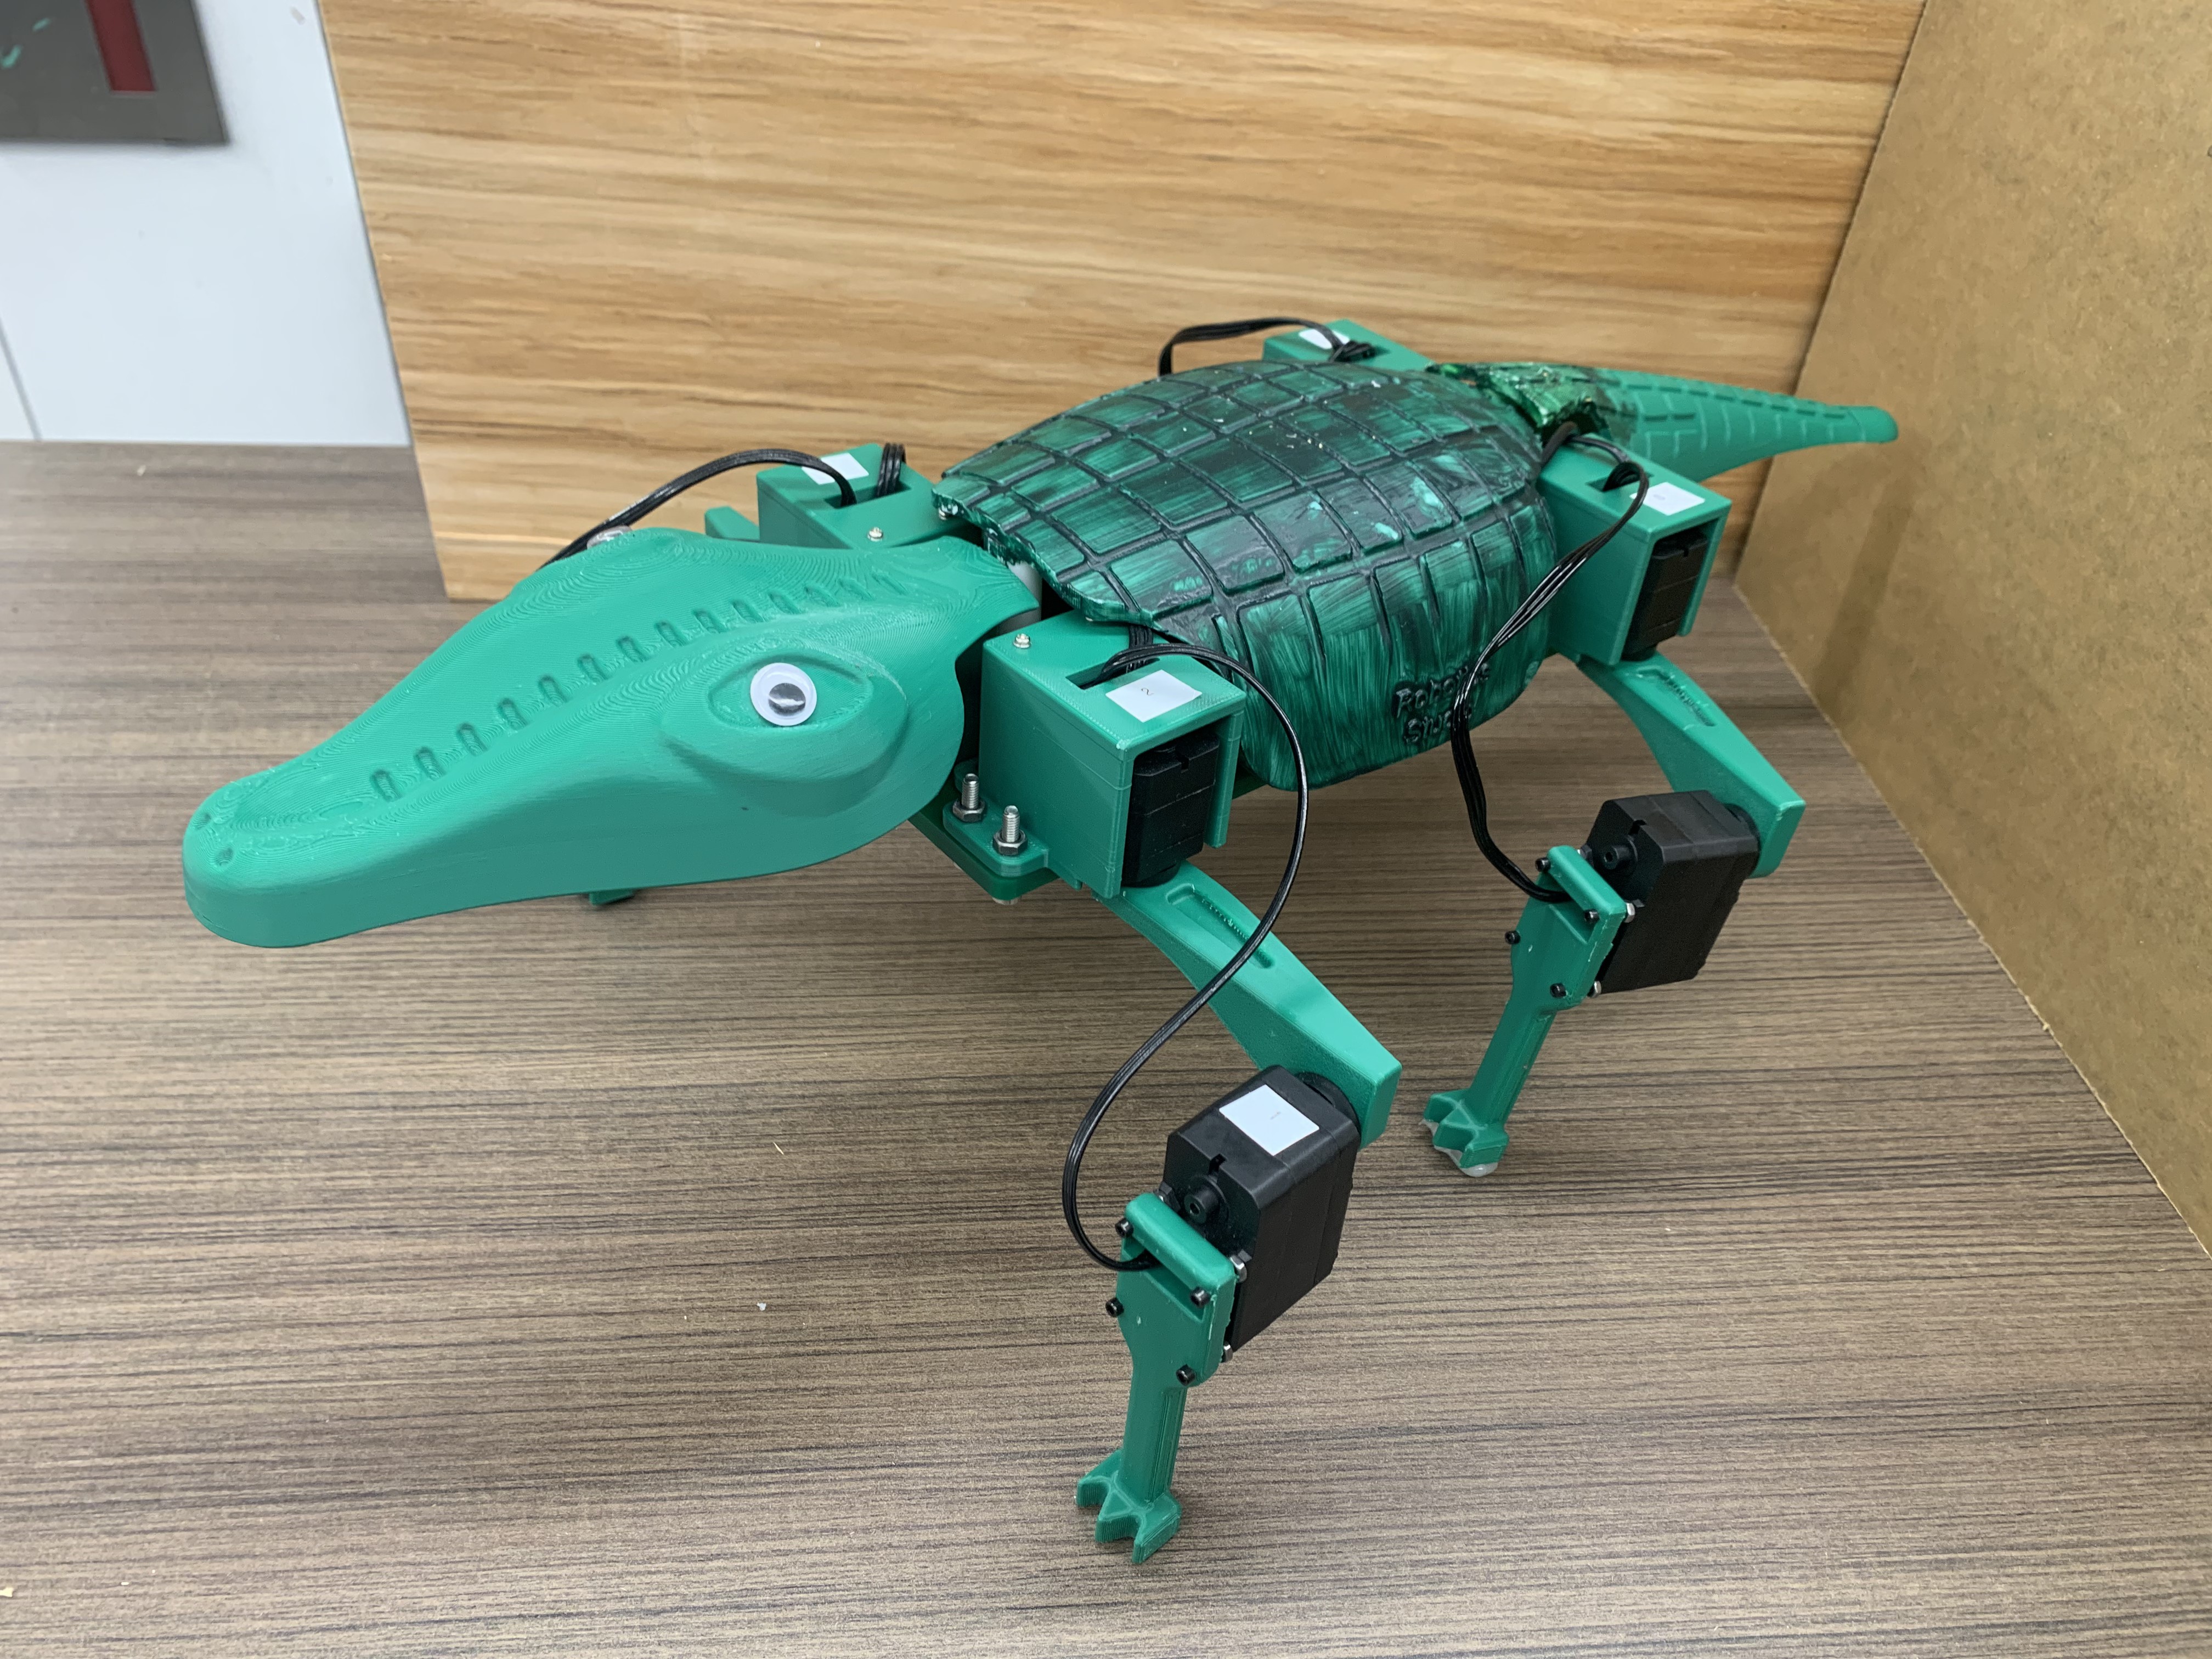
Photo
About This Project
This project involved designing and prototyping a bio-inspired quadrupedal walking robot modeled after crocodile locomotion. The robot uses a synchronized linkage mechanism to coordinate all four limbs, producing stable and repeatable gait patterns.
Two distinct gait modes were implemented — a fast walk and a slow walk — each validated through video analysis and physical prototype testing at Columbia University's robotics lab.
Course
Robotics Studio — Columbia
Year
2024
Skills
Mechanical Linkages, Gait Design, Physical Prototyping
Outcome
Functional walking prototype — dual gait modes